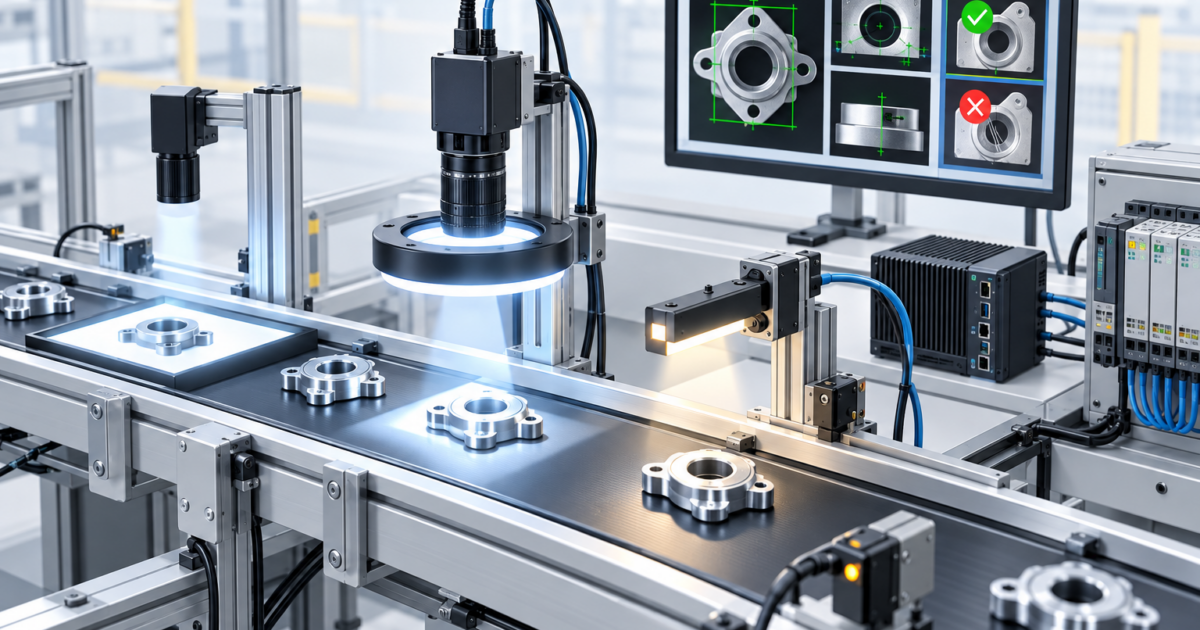
“How small can a 2-megapixel camera measure in µm?” “We can’t reliably detect scratches on metal surfaces.” “Images captured on high-speed production lines come out blurry.” —When implementing image processing into equipment, you’ll face challenges like these.
In FA (Factory Automation) image inspection, performance isn’t determined by the camera’s pixel count alone. It’s important to determine the field of view, lens, lighting, exposure time, image processing, coordinate calibration, and integration with the PLC by working backward from the inspection objectives.
This article is a practical guide for mechanical, electrical, and control designers, covering everything from the basics of image processing and camera selection to numerical accuracy evaluations, tips for equipment implementation, and trends for 2026—including AI, 3D, high-speed video, and event-driven cameras. While retaining traditional design drawings and calculation examples, it supplements the technical content to ensure that measurement accuracy and pixel resolution are not confused.
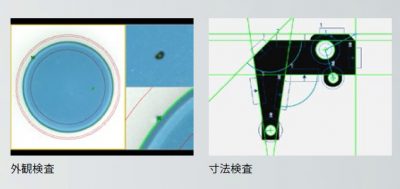
Example of a conventional image processing system: KEYENCE CV-X Series (Reference: CV-X Series).
1. Image Processing System Design Procedure | Decisions to Make Before Purchasing a Camera
Broadly speaking, the purposes of image processing equipment include “Presence/Absence and Pass/Fail Judgment,” “Dimension and Position Measurement,” “Identification and Character Recognition,” “Visual Inspection,” “3D Position and Shape Measurement,” and “Motion Analysis Using Video.” First, determine the inspection purpose and pass/fail criteria, then design the optics and control system as an integrated unit.
| Design Items | Items to Confirm First | Decisions Made During Design |
|---|---|---|
| What to Do | Measurement, positioning, defect/missing part detection, robot guidance | 2D/3D, black-and-white/color, AI/rule-based |
| What to Inspect and How | Inspection surface, material, color, gloss, minimum defect size | Capture direction and lighting method |
| Distance and Field of View | Installation Space, Working Distance (WD), Workpiece Variation | Lens, Image Sensor, Focal Length |
| Accuracy and Speed | Tolerances, Inspection Cycle, Line Speed, Exposure Time | Required Pixel Count, Sensor, Processing Performance |
| Maintenance | Calibration cycle, contamination, lighting degradation, recipe switching | Fixtures, inspection items, log and image storage |
| Control Integration | Output to PLC, capture trigger, distance to discharge | Signal specifications, allowable delay, handling during failure |
Design Fundamentals: Instead of “Select a camera → Plan the inspection,” consider the process in the following order: “Inspection requirements → Required pixel scale → Field of view and optics → Lighting → Capture and evaluation cycle.”
What can image processing do?
- Pattern and Model Search:Presence/absence determination and position detection by comparing with pre-registered images
- Edge and Circle Detection:Outline, hole diameter, center, and gap measurement
- Color Judgment:Verification of label colors, identification marks, and print quality
- AI-Based Appearance Judgment:Classification and anomaly detection of irregularly shaped contaminants, scratches, foreign objects, etc.
- Video and Time Series:Observation of assembly timing, conveyor issues, and momentary snags
2. Basics of Pixel Count, Subpixels, and Bayer Arrays
Pixel count does not refer to “resolution,” but rather to how finely an image is divided
2 million pixels (2MP) means the image can be represented using approximately 2 million pixels. If you widen the field of view with the same camera, the actual physical size represented by each pixel increases, making it harder to capture small defects. Conversely, narrowing the field of view makes it easier to capture fine details even with the same number of pixels.
Object-side pixel scale (mm/pixel) = Field of view width (mm) ÷ Horizontal pixel count (pixels)
However, the pixel scale isdistinct from measurement accuracy and guaranteed detection dimensions. Factors such as lens resolution, light intensity, contrast, sensor noise, distortion, and calibration must also be taken into account.
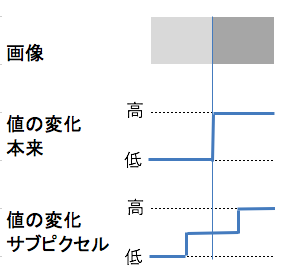
What is subpixel processing?
This is a process that estimates edge positions based on the luminance distribution of adjacent pixels to determine positions finer than a single pixel. For example, even with a pixel scale of 10 µm/pixel, it may be possible to detect position changes of less than one pixel for edges with good reproducibility. However, this does not increase the camera’s physical pixel count, nor does it guarantee that measurement accuracy will always be 0.1 pixels.
What is the Bayer array in color cameras?
Typical single-chip color sensors place red (R), green (G), and blue (B) color filters over the pixels and use interpolation (demosaicing) to create color images. Since adjacent pixels do not directly capture the same color information, the impact of interpolation must be evaluated when analyzing fine patterns or performing position measurements.
If color is not a requirement, a monochrome camera may offer advantages. However, it is not possible to make a blanket statement such as “color always halves accuracy.” Accuracy varies depending on the sensor, optical system, and algorithms.

3. Selecting Cameras and Lenses | Calculating Field of View and Measurement Accuracy
Working Distance (WD) and Field of View (FOV)
Working distance is typically defined as the distance from the front of the lens to the workpiece (check the product specifications). The field of view is determined by the combination of the lens, image sensor, and WD. Use the manufacturer’s WD–FOV chart to find a combination that fits your installation dimensions.
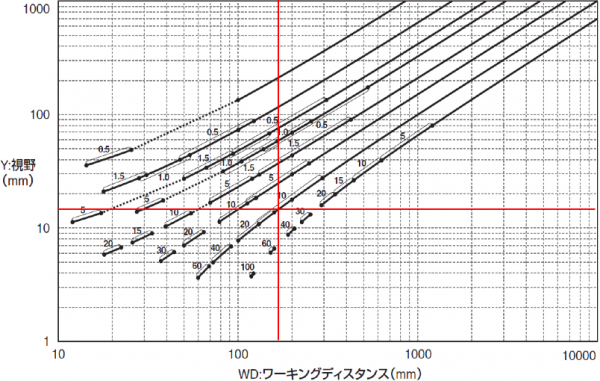
Calculation example: 1.92 million pixels, 11 mm field of view
If the image size is 1,600 × 1,200 pixels and the field of view is 11 × 8.25 mm, the horizontal pixel scale is as follows:
11 mm ÷ 1,600 pixels = 0.006875 mm/pixel = 6.875 µm/pixel
This calculation shows how many pixels are used to sample the imaging area. For example, a 20 µm defect corresponds to approximately 2.9 pixels; however, whether it is visible depends greatly on the defect’s contrast, shape, and imaging conditions. This does not indicate the guaranteed accuracy of dimensional measurements.
Latest design example: Detecting a 50 µm-wide scratch
Here, we use at least 5 pixels as a guideline for the initial design. This is an empirical starting point and does not guarantee that all scratches of this width will be detectable.
- Target to be detected: 0.05 mm (50 µm) wide
- Design guideline: 5 pixels/ Scratch width
- Permissible pixel scale: 0.05 mm ÷ 5 = 0.01 mm/pixel
- Required field of view width: 40 mm
- Required number of horizontal pixels: 40 mm ÷ 0.01 mm/pixel = 4,000 pixels or more
With 4,096 horizontal pixels, the object-side pixel scale is approximately 9.77 µm/pixel, meaning a 50 µm scratch would span approximately 5.1 pixels. In practice, please verify this using both good and defective samples, taking into account scratch depth, lighting, resolution, depth of field, and imaging variations.
Distortion (Lens Distortion)
Straight lines may appear curved at the edges of the lens, and the magnification may vary depending on the location. When measuring dimensions on drawings or outputting coordinates, it is necessary to correct for scale differences caused by the shooting position.

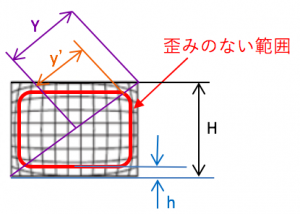
Schematic diagrams of optical distortion and TV distortion are also included for reference.However, since the definitions and measurement positions differ between the two, it is not possible to simply multiply the percentage values by the field of view width to determine the “usable range.” Check the definitions specified by the manufacturer and use a calibration plate to verify that the required positional accuracy is met.
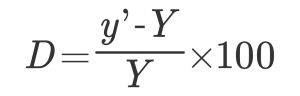
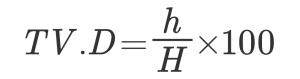
For high-precision dimensional measurement, telecentric lenses are also considered. While they can minimize changes in magnification and perspective effects caused by variations in workpiece height, there are trade-offs involving lens diameter, cost, required illumination, and field of view conditions.
Out-of-focus areas and the permissible circle of confusion
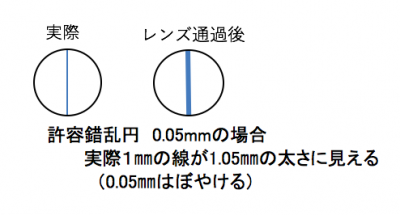
The permissible circle of confusion is a design criterion that determines “how much out-of-focus area is acceptable,” and it is determined based on inspection requirements and optical conditions.It is not the case that one pixel’s worth of out-of-focus area is unconditionally permissible.Nor is it possible to simply add the amount of out-of-focus area to the pixel scale to determine “overall accuracy” or “minimum detectable width.”
How is measurement accuracy evaluated?
When evaluating the quality of measurement values, at least the following aspects must be examined separately.
- Resolution: Actual physical dimensions per pixel; effective optical resolving power
- Repeatability: The degree of variation in values during consecutive measurements of the same workpiece
- Accuracy and calibration residuals: Deviation from the reference instrument and positional errors
- Stability:Drift caused by temperature, vibration, lighting degradation, and changes in workpiece height
If the uncertainty can be evaluated as a sum of independent, random components, the combined standard uncertainty can be treated as the square root of the sum of the squares; however, if systematic errors are present, correction and residual management are required. Verify whether the measurement system has sufficient performance relative to the product’s tolerance limits through repeatability tests, calibration, GR&R, etc.
Points to Note Regarding Lens Mounts
Types include C-mount, CS-mount, M12, and F-mount. Verify not only the mounting dimensions but also the flange back, image sensor size (image circle), lens resolution performance, aperture, mounting method, and vibration countermeasures.
4. Lighting Selection | Sometimes It’s Better to Improve the Lighting Before Adjusting the Camera
Image processing relies on the differences in brightness and color between the features you want to detect and the background.If you’re having trouble with image processing, first consider whether you can use lighting to make the features stand out.
| Purpose | Examples of Lighting Methods | Points to Note |
|---|---|---|
| Measuring outer shapes, holes, and contours | Transmitted light/backlight | Contour blurring, scattering, and alignment |
| Printed markings and flat surfaces on glossy parts | Coaxial incident light/brightfield | Angle of specular reflection, surface tilt |
| Fine Scratches and Irregularities on Metal Surfaces | Low-Angle Dark-Field and Oblique Illumination | Scratch Orientation and Uneven Reflection |
| Measures to Prevent Reflections on Curved Surfaces and Packaging Film | Dome Illumination and Diffused Illumination | Illumination Size and Light Intensity |
| Partial Highlighting and High-Speed Photography | Bar Lighting, Spot Lighting, and Strobes | Illuminance, Heat Generation, and Synchronization |
| Color Identification | White Lighting and Color Cameras | Lighting Spectrum and White Balance |
While guidelines such as “use blue-toned lighting for scratches” or “use front lighting for metals” may be effective under certain conditions, they are not universal solutions. Depending on the surface gloss, roughness, and orientation of the scratches, dark-field illumination, oblique lighting, polarizing filters, and wavelength selection should be compared and evaluated.
For example, shallow scratches on metal surfaces may become more visible when low-angle lighting is used to capture the scattered light from the scratches. On the other hand, coaxial illumination may be advantageous for flat engravings or printing. The most reliable approach is to bring in a sample and evaluate it under actual conditions, including the equipment’s orientation, ambient light, and oil contamination.
5. F-Number and Depth of Field | Maintaining Focus Even When Height Changes
What Is the F-Number?
The F-number is the focal length divided by the effective aperture. Generally, increasing the F-number (closing the aperture) reduces the amount of light entering the lens and increases the depth of field. However, closing the aperture too much reduces resolution due to diffraction, so the smallest aperture is not always the best choice.
Understanding Depth of Field
Depth of field (DOF) is the range of depth within which acceptable sharpness is maintained even if the position of the workpiece changes. For example, if the product height varies by ±0.5 mm, the optical system is selected so that inspection performance is maintained at least within that range.
As a first-order approximation for close-up photography, assuming a magnification of 1, the following formula is used: DOF ≈ 2cN(1+M)/M² (c: permissible circle of confusion on the image plane; N: nominal F-number; M: magnification). Since actual calculations depend on the lens structure, permissible bokeh, sensor, and telecentricity, please verify these values using the manufacturer’s specifications and actual measurements.
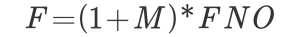
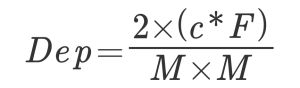
The formulas and figures are provided for reference. For example, in an approximation where M = 0.8, N = 2, and c = 0.01 mm, the DOF is approximately 0.113 mm. However, this is a calculation example derived from the specified conditions and does not guarantee the measurement accuracy of the designed inspection.
Implementation tips for the field: If the image becomes darker as a result of stopping down the aperture, consider increasing the illumination level or using a strobe before extending the exposure time. This is because extending the exposure time during high-speed transport increases motion blur.
6. Aligning Image Coordinates with Machine Coordinates | Calibration and Coordinate Transformation
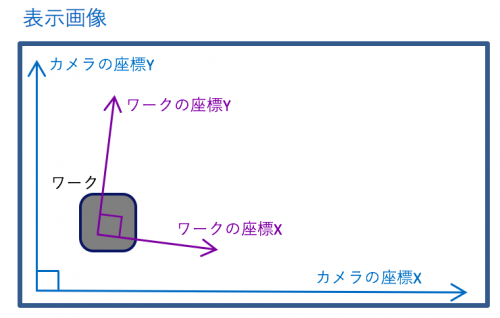
Even if the center of a hole detected in the image is at (x, y) = (820, 560) pixels, that information alone is not sufficient to move the robot or XY table. The coordinates in the camera image must be converted to the actual machine coordinates (X, Y).
What determines the coordinate transformation method?
- Rotation, translation, and constant scaling:Use rigid transformations or similar transformations between orthogonal plane coordinate systems. If additional conditions exist—such as a known scaling factor—the transformation may be determined from the decimal point.
- Shear or different scaling factors along each axis:Affine transformation. For a general 2D affine transformation, at least three corresponding points on a non-straight line are required.
- Projective distortion due to camera tilt:Planar homography. Generally, at least four pairs of corresponding points are required.
- Lens distortion and 3D height changes:Consider distortion correction, internal and external camera parameters, 3D calibration, etc.
An explanation of coordinate transformations using the rotation angle θ and scale factor is also useful as a concept for simple calibration using rotation and scale. Expressing this as a matrix aligned with the equipment’s coordinate system, axis directions, signs, and origin can reduce implementation errors.
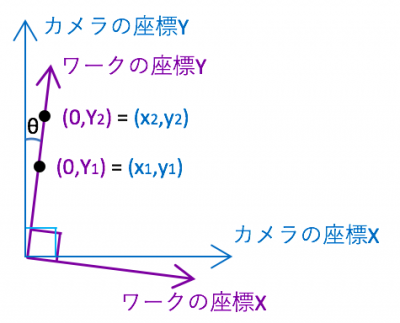
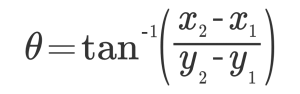
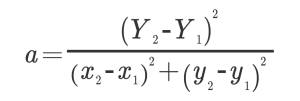
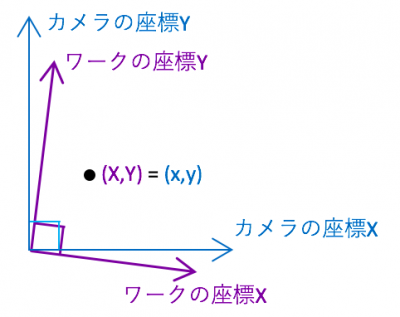
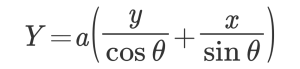
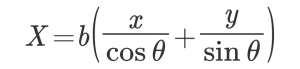
However, this does not mean that “capturing just two points will allow any image to be correctly converted to workpiece coordinates.” In practice, it is recommended to place calibration points at multiple locations within the field of view and verify residuals using verification points not used for calibration. Be sure to check the calibration status after the machine returns to its origin, after a camera replacement, or after reassembling the fixture.
7. Methods for Stabilizing Model Search and Edge Detection
How to Determine the Detection Range (ROI)
The ROI (Region of Interest) is the inspection area within an image. Making it smaller can reduce processing time and false detections, but if it is too narrow, the target may be lost due to positional variations.
The detection range should be determined by estimating the assembly tolerances of the equipment, guide play, workpiece machining errors, stop position repeatability, and posture variations. Do not simply add up all tolerances; clearly define whether the design guarantees the worst-case scenario or manages variations through statistical methods.
Three Tips for Stabilizing Model Search
- Use areas with sufficient distinctive features as the model, rather than repetitive patterns.
- Limit the rotation angle, scale, and detection ROI to the necessary range.
- Measure correlation values and false recognition rates under variations in good parts (lighting, scratches, lot, orientation).
Model search is not a panacea. In cases of similar patterns or strong reflections, improving machine positioning or lighting can be effective.
Reducing Errors in Edge Detection
Edge detection captures changes in brightness, but the detection position varies depending on blur, lighting angle, and material. Do not rely solely on threshold adjustment; verify the edge profile, direction, noise, and lens distortion.
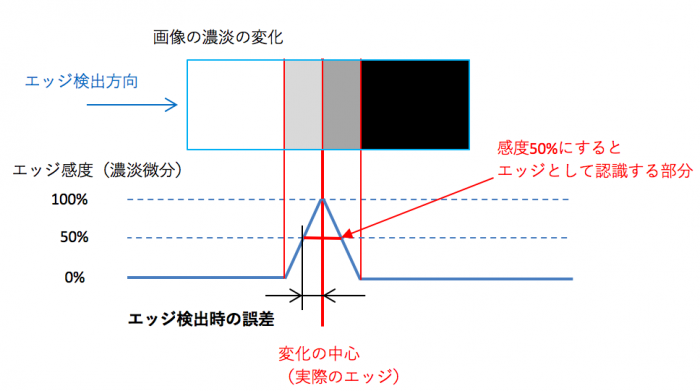
The method of finding edges on both sides and determining the center is often effective for detecting the positions of holes, grooves, and part centers.
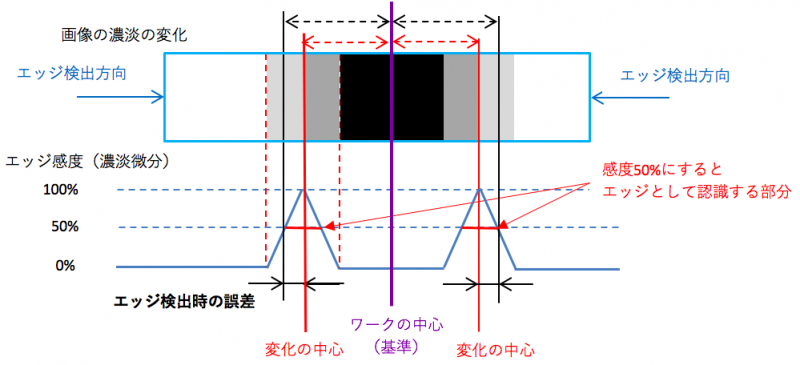
Note: The “center of both edges” does not always correspond to the “actual center” of the object. Bias may remain due to asymmetrical lighting, reflections, shape, or blurring. Please verify the measured values using a reference standard or a calibration workpiece.
8. Capturing Fast-Moving Workpieces | Shutter, Video, and PLC Design
The Difference Between Global Shutter and Rolling Shutter
Global shutter exposes the entire frame simultaneously and is suitable for high-speed transport, position measurement, and robot tracking. With a rolling shutter, the exposure timing shifts row by row, which can cause distortion—such as high-speed moving objects appearing tilted. Motion blur occurs with both types if the exposure time is too long.
Calculating Exposure Time: For a line speed of 500 mm/s
The distance an object travels is equal to “velocity × exposure time.” If you want to limit the blurring in the image to 10 µm (0.01 mm) or less,
Permissible exposure time ≤ 0.01 mm ÷ 500 mm/s = 0.00002 seconds = 20 µs
Since such a short exposure time can easily result in insufficient brightness, the design takes into account strobe lighting, high-sensitivity sensors, and the lens’s f-number. Note that these calculations are approximations based on the workpiece moving parallel to the imaging plane.
What is the difference between still image inspection and video monitoring?
| Applications | Recommended Approaches | Design Considerations |
|---|---|---|
| Presence, Dimensions, and Markings of Parts | Trigger-Synchronized Still Image Inspection | Exposure, Illumination, and Positioning Accuracy |
| Continuous inspection during high-speed transport | High-fps area cameras/line scan | Transport encoder, bandwidth, and synchronization |
| Momentary jamming and assembly errors | High-speed video and pre- and post-event recording | fps, shutter, and pre-trigger |
| Robot grip posture | 2D position recognition / 3D ToF and stereo | Coordinate calibration, latency, and occlusion |
| Abnormal vibrations and high-speed motion | High-speed video / event-based | Temporal resolution and analysis algorithms |
Calculating Video and Image Data Transfer Rates and Storage Capacity
For example, consider uncompressed video at 1920×1080 pixels, Mono8 (8 bits per pixel), and 120 fps.
Data volume per second = 1920 × 1080 × 1 byte × 120 fps = 248,832,000 bytes/s ≒ 249 MB/s (approx. 1.99 Gb/s)
Saving 10 seconds of this footage results in approximately 2.49 GB of video data alone. This is a rough estimate that excludes communication overhead (such as headers), metadata, and file format overhead. Under the same conditions, 8-bit color (RGB24) would result in approximately three times that amount.
This uncompressed data transfer is difficult to achieve with the effective bandwidth of 1 GigE. We will consider high-speed connections such as 10GigE and CoaXPress, as well as reducing the region of interest (ROI) and frame rate, onboard recording, and compression methods. However, lossy compression such as H.264/H.265 may not be suitable for images used to measure minute defects. It is reasonable to design the original images for inspection and the surveillance video for human verification separately.
Practical Implementation of PLC Integration and Defect Ejection
- Receive capture triggers from photoelectric sensors or encoders.
- Synchronize the camera’s exposure with the strobe flash.
- Link the inspection target ID, capture time, and encoder position.
- Notify the PLC of OK/NG status, measurement values, and completion of processing from the image processing unit.
- Calculate the NG ejection timing based on the distance to the ejection position, conveyor speed, and response delay.
- Define safety-oriented handling procedures for timeouts, communication failures, missed captures, and unevaluated images.
On high-speed lines, evaluate not only the “camera’s fps” but also the maximum latency and jitter in the sequence: exposure → transfer → processing → PLC reception → ejection actuator . When using multiple cameras, time synchronization such as PTP (IEEE 1588) may be useful; however, verify compatibility with the equipment and network.
9. Latest Trends in FA Cameras [As of October 2026]
The fundamental principle mentioned in previous articles (as of 2017)—“capturing good images”—remains important today. Meanwhile, in the FA sector of 2026, the use of camera-side AI processing, 3D information, edge processing, high-speed interfaces, and video recording during anomalies is becoming more widespread. The following is an overview based on information published by manufacturers and standardization organizations.
① AI Image Inspection: Using Rule-Based and Machine Learning Approaches Appropriately
For fixed dimensions, clear shapes, and barcode reading, traditional rule-based processing may offer advantages in terms of explainability and reproducibility. On the other hand, for issues with significant variations in appearance—such as dirt, scratches, or molding irregularities—learning-based image processing can be considered.
Products such as Keyence’s VS Series and VS-G Series, Cognex’s In-Sight D900, and MVTec’s HALCON offer visual inspection solutions that utilize AI and deep learning. However, AI does not guarantee stability under all conditions; it requires the collection of data on good and defective products, consideration of lighting conditions, evaluation of false positives and missed defects, and change management during retraining.
Official Manufacturer Site: Keyence Image Processing Systems (VS/VS-G/CV-X) / Cognex In-Sight D900 / MVTec HALCON 25.11
② 3D Cameras: Measuring Height, Orientation, and Stacking
2D cameras are suitable for inspecting the shape and color of flat surfaces. By using 3D ToF (Time-of-Flight), stereo, or laser profiling, it is possible to measure the height, depth, and tilt of an object, as well as estimate its orientation during robotic picking. However, the most suitable method varies depending on whether the surface is transparent or reflective, the presence of obstructions, ambient lighting, and the required depth accuracy.
③ Event-Based Cameras: Capturing Changes Rather Than the Entire Image
Event-based cameras capture the position, polarity, and timestamp of luminance changes at each pixel. While they can efficiently capture temporal information from high-speed vibrations or moving objects, they are not suitable for applications that require standard still color images. Rather than replacing conventional area cameras, they should be used selectively based on the specific application.
IDS Official Site: How Event-Based Cameras Work and Their Applications
④ High-Speed Recording: Reviewing Brief Equipment Malfunctions Using Surrounding Video Footage
With assembly machines and conveyors, it can be difficult to pinpoint the cause of momentary jams, material scatter, or collisions using only standard still images. By linking high-speed camera recordings with PLC alarms or sensor signals and storing several seconds before and after the incident in a ring buffer, you can facilitate root cause analysis and implement countermeasures against micro-stops.
In July 2026, Allied Vision announced an SMR 10GigE camera capable of up to 2,517 fps in Full HD with 32 GB of onboard storage. This is just one example of a high-speed recording device; it is necessary to verify the full resolution, recording time, lighting conditions, and transfer speed under actual system conditions.
Allied Vision Official Site: SMR 10GigE High-Speed Recording Camera (July 2026)
⑤ Camera Interface: GigE Vision 3.0・GenICam
| Standard | Features | Suitable Applications |
|---|---|---|
| GigE Vision | Uses Ethernet, offering flexibility in cabling distance and network design | Distributed placement within facilities; configurations with multiple units |
| USB3 Vision | Easy to connect directly to a PC; supports high-speed data transfer | Short-distance connections; compact devices |
| CoaXPress | High-bandwidth transmission; often used in configurations with frame grabbers | High-resolution, high-fps, and high-speed lines |
| GenICam | A software standard that unifies access to camera functions | Standardization of implementation across manufacturers |
In April 2026, GigE Vision 3.0 was approved, adding a new streaming method using RoCEv2. However, standard approval does not mean that it is immediately available on all cameras, NICs, and switches. Check product compatibility and network configuration.
A3 Official: GigE Vision 3.0 / EMVA Official: GenICam / JIIA: Machine Vision Standards
⑥ Learn the Latest in FA Image Processing Through Videos (Official Manufacturer Content)
- IDS “VISION 2026 Machine Vision Tour” : Explanatory videos featuring exhibits such as event-based systems, 3D ToF, AI object detection, and multi-camera systems.
- IDS “Event-based imaging – increased speed, less data”: A video explaining the principles of event-based cameras and their applications in factory automation.
- MVTec “Deep-Learning-Based Anomaly Detection” : An explanatory video covering the procedures for creating and evaluating anomaly detection models.
*Please check the official pages of each manufacturer for video playback requirements, embedding permissions, and product information. We do not repost manufacturers’ videos without permission; instead, we provide links to their official pages.
10. Practical Design Example: Visual Inspection of Metal Parts on a Conveyor
Assumed Specifications: Detection of the presence of metal parts, hole positions, and scratches 50 µm wide. Field of view: 40 mm; conveyor speed: 500 mm/s. These are hypothetical conditions provided for illustrative purposes.
- Requirement Definition: Clearly define not only the width of the scratch but also its depth, length, direction, miss rate, false positive rate, and dimensional tolerances.
- Camera: If the design guideline is to capture a 50 µm feature with 5 pixels, consider a camera with at least 4,000 horizontal pixels as an initial candidate.
- Lens: Verify the required working distance (WD), field of view, image circle, and resolution performance. Perform distortion correction for dimensional measurement.
- Illumination: Evaluate actual samples using backlighting for hole positions and low-angle illumination for fine scratches on metal surfaces.
- Exposure: Based on initial calculations limiting blur to 10 µm or less, the exposure time should be 20 µs or less. Consider strobe synchronization.
- Control: Connect the PLC to the image capture trigger, measurement values (OK/NG), the ID of the part to be ejected, and the timeout.
- Evaluation: Verify performance by varying the lot, material variations, contamination, temperature, vibration, lighting degradation, and workpiece height.
- Maintenance: Manage lighting intensity, focus, calibration residuals, camera mounting, images of good and defective products, and AI model update history.
Pre-launch Checklist
- Is the required image quality maintained even at the worst position within the field of view?
- Was the evaluation performed not only on representative samples of good and defective products but also on boundary samples?
- Are there any missing frames, temperature rises, or network congestion during continuous operation?
- Can the system transition to a safe state in the event of a PLC undecided status or communication error?
- Are there recalibration procedures in place for lens replacement, fixture changes, and lighting replacement?
- Have you established retention periods, access rights, and deletion rules for images, videos, and inspection logs?
11. Frequently Asked Questions (Q&A)
Q1. Can a 2-megapixel camera measure 10 µm?
A. This cannot be determined by pixel count alone. It depends on the field of view width, lens, calibration, detection method, and repeatability. For example, with an 11 mm field of view and 1,600 horizontal pixels, the resolution is 6.875 µm/pixel; however, this alone does not guarantee “10 µm measurement accuracy.”
Q2. Which is better: a color camera or a monochrome camera?
A. If color identification is required, use a color camera; if the focus is on shape, contrast, or fine edges, a monochrome camera is also a strong option. Compare both using sample images and under the same lighting conditions.
Q3. Can subpixel processing guarantee the detection of defects smaller than one pixel?
A. Detection is not guaranteed. Subpixel processing is a method for estimating position; limitations related to the imaging contrast of defects and optical resolution still apply.
Q4. How can we improve accuracy while maintaining a wide imaging field of view?
A. Consider options such as using high-resolution cameras, employing multiple cameras, local high-magnification imaging, or line-scan systems. Simultaneously evaluate the required speed and data transfer volume.
Q5. What type of lighting is best for detecting fine scratches on metal parts?
A. One approach is to compare options such as low-angle dark-field illumination or oblique lighting. However, the appropriate illumination varies depending on the direction of the scratch, surface finish, and gloss.
Q6. Does a global shutter prevent blur even when the object is moving?
A. No. Even with a global shutter, blur caused by movement during the exposure time can occur. Calculate the exposure time based on the speed and the allowable blur margin.
Q7. Does using AI image inspection eliminate the need for lighting adjustments?
A. No, it does not. Performance may decline if imaging conditions change between the training phase and mass production. Stable lighting, fixtures, and inspection conditions are crucial.
Q8. Are two points sufficient for calibrating coordinate transformations?
A. It depends on the transformation model.For simple models involving only magnification and rotation, calibration with a few points may be possible; however, general affine transformations require three points on non-parallel lines, and planar projection transformations require four or more corresponding points. It is recommended to verify residuals using additional points.
Q9. Can video recording and image inspection be performed with the same camera?
A. This may be possible with compatible models.However, you’ll need to consider factors such as uncompressed recording of source images for inspection, compression of video for monitoring, frame rate (fps), onboard memory, and integration with PLC events.
Q10. How do I integrate the camera with the factory’s PLC?
A. Depending on the specifications of the camera and controller, select from options such as digital I/O, Ethernet/IP, PROFINET, proprietary communication protocols, or OPC UA. Be sure to design not only the data items but also the cycle, timeout, and behavior in the event of equipment failure.
Q11. Are 3D cameras superior to 2D cameras?
A. They serve different purposes.While 3D cameras are effective when height and depth information is required, 2D cameras may be simpler and better suited for inspecting flat-surface dimensions, colors, and printed markings, often offering higher in-plane resolution.
Q12. How can image processing equipment be kept stable over the long term?
A. Regular checks of imaging conditions and change management are crucial. Manage lens dirt, lighting intensity, calibration errors, PLC communication, software and AI model versions, and the accumulation of images of good and defective products.
Summary | Image processing is more about “overall design of optics, control, and verification” than “pixel count”
When selecting an image processing camera, it is most important to first determine what to detect and under what conditions. Determine the pixel scale based on the number of pixels and the field of view; select the lens, lighting, and shutter; verify image processing and coordinate calibration; and evaluate the system, including latency and traceability with the PLC.
While the latest factory automation (FA) technologies—such as AI, 3D, event-based systems, and high-speed recording—are expanding the range of options, the fundamentals—ensuring features are captured consistently and verifying the required reproducibility through actual measurements—remain unchanged. Don’t rely solely on catalog specifications; evaluate systems under the worst-case conditions during mass production to design reliable image inspection equipment.
Reference Materials and Related Links
- JIIA: Machine Vision Standards
- EMVA: GenICam
- A3: GigE Vision Standard
- Basler: Global/Rolling Shutter
- KEYENCE: Basics of Lighting Selection
- Allied Vision: High-Speed Recording Cameras
- OPC Foundation: OPC UA for Machine Vision
Technical information verified: October 26, 2026. The selection calculations are provided as illustrative examples. Please base your final design on your requirements, manufacturer specifications, and test results.